Physical AI & Sim-to-Real
Physical AI & Sim-to-Real
AI systems that perceive and act in the physical world, using physics-based simulation to generate training data and bridge the gap to real environments.
- Physics-based simulation and synthetic data generation
- Sim-to-real gap analysis
- Embodied control for robotic manipulators on embedded and neuromorphic hardware
Research Area Overview
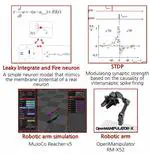
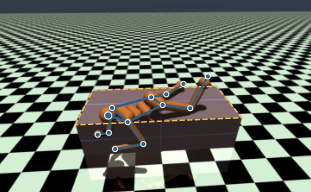
We build AI systems that perceive and act in the physical world, using physics-based simulation to generate training data and closing the gap between simulated and real environments. Our work spans patient fall detection for smart hospital beds and energy-efficient control of robotic manipulators, with an emphasis on models light enough to run on embedded and neuromorphic hardware.
Focus Topics
- Physics-based simulation and synthetic data generation for data-scarce physical domains
- Sim-to-real gap analysis between simulated dynamics and real-world sensing
- Embodied control for robotic manipulators on embedded and neuromorphic hardware
- Lightweight, real-time models deployable on embedded clinical and robotic edge devices