Reinforcement Learning
Reinforcement Learning
Reward-driven agents that learn which biosignal features and decisions matter most, from ECG-based authentication to EMG-driven device control.
- RL-based feature selection over ECG and EMG descriptors
- Reward shaping and curriculum design for sample-efficient learning
- Decision-making policies for biometric and assistive applications
Research Area Overview
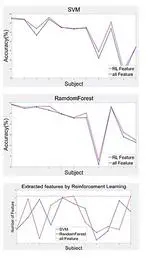
Our reinforcement learning (RL) portfolio focuses on decision-making and feature selection over biosignals. We develop agents that learn which descriptors of ECG, EMG, and other physiological streams carry the most value, then use those agents to drive classical classifiers and simulated decision environments.
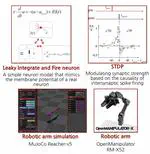
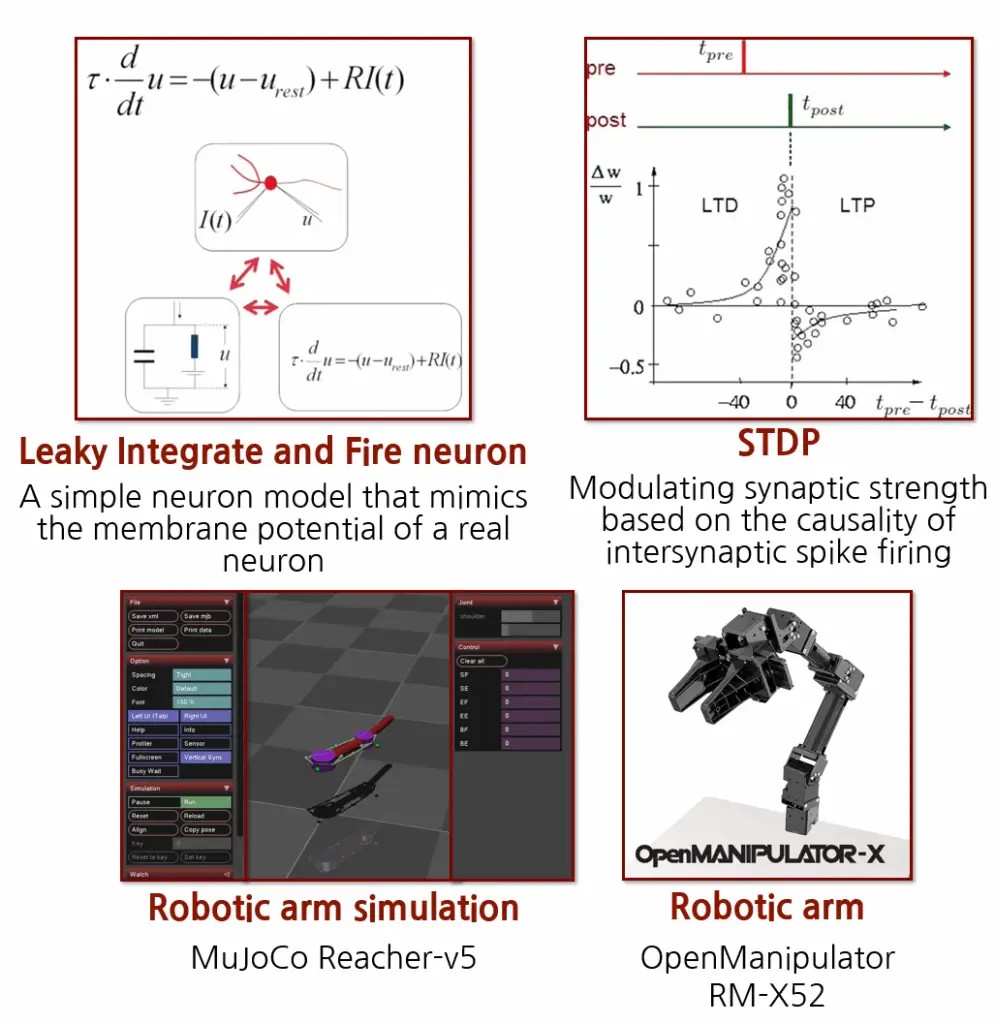
Our work on embodied, neuromorphic robotic control is also showcased in the Physical AI & Sim-to-Real research area.
Focus Topics
- RL-driven feature selection for ECG-based personal authentication
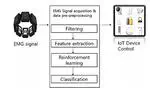
- RL-driven feature selection for EMG-based prosthetic and rehabilitation control
- Reward shaping and curriculum design in simulated decision environments
- Sample-efficient policy learning over noisy, high-dimensional biosignals